01
Autonomous Launcher
Launches tennis balls to specific bounce locations with controlled spin, speed and height, adjusting trajectory in real time in response to the player.
Build it yourself. Build it better.
Open hardware / Open softwareOpen tennis robot project
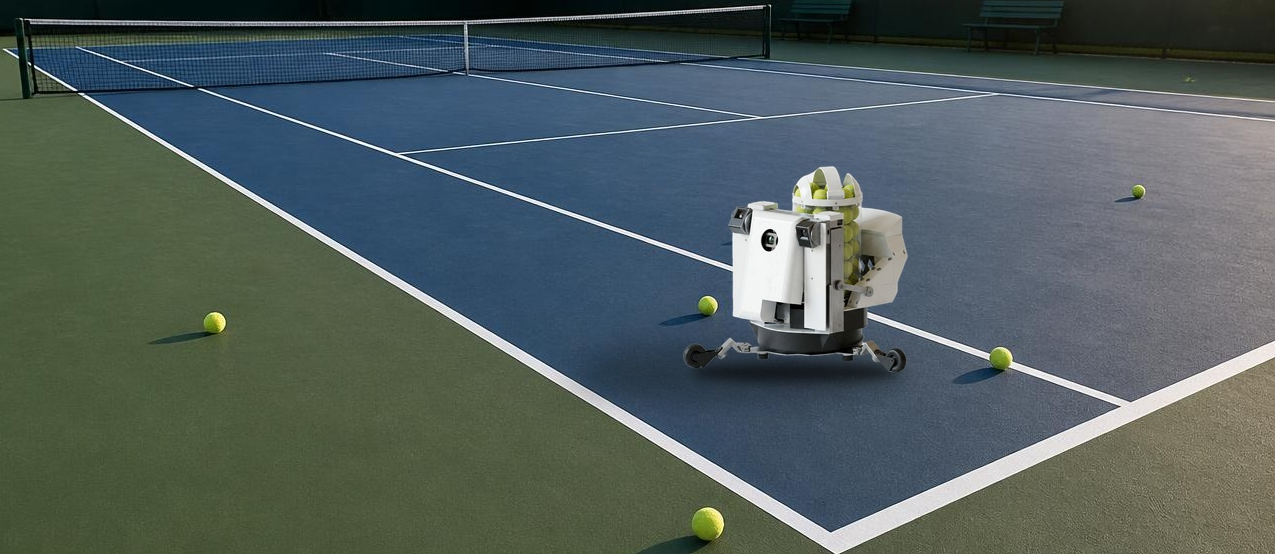
The BallBOPPer™ is an autonomous tennis robot and a tennis tactics and strategy research platform. It plays points, games, sets and matches in the style of a specific opponent — and soon every model, design file, and line of software behind it will be open-source and available to use.
Latest Lab Notes
Platform capabilities
Launches tennis balls to specific bounce locations with controlled spin, speed and height, adjusting trajectory in real time in response to the player.
Elevates the launch head dynamically to realistically simulate the heights that a real player hits from. This greatly increases realism especially for serving.
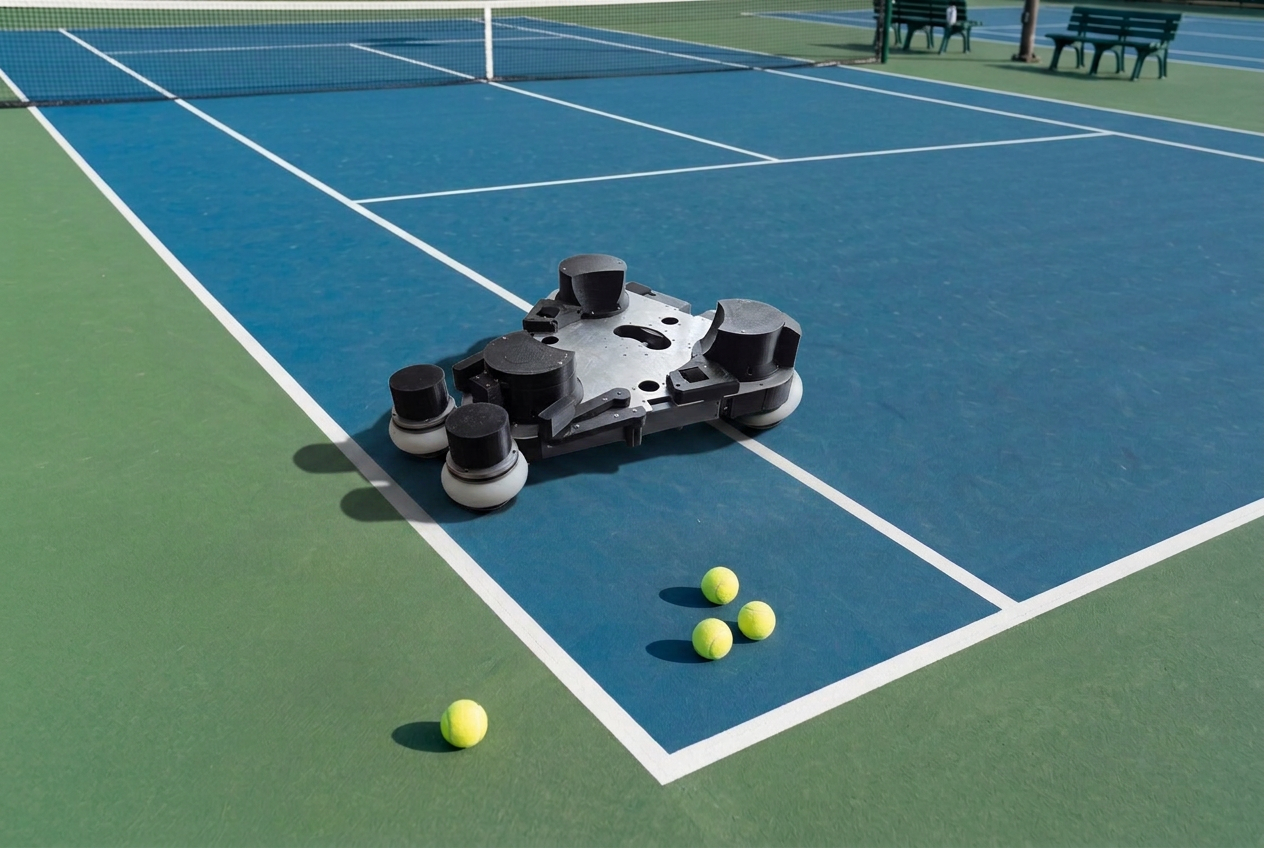
Transports the launcher around the court at human-like speeds, launching from positions based on the trajectory of each returned ball.
Attaches to the rover to collect balls and return them to the ball revolver at high speed so practice time is spent on skills rather than picking up balls.
Runs the tennis AI models on an iOS, Android, Windows or Mac. Can be combined with Bluetooth headset for voice control and coaching feedback.
Fits in a car, rolls like luggage, runs on removable interchangeable batteries, and works on any standard court with no installation.
Plays points, games, sets and matches while simulating the competitive playing style of one of your actual upcoming opponents.
Additional features are currently in development and testing including the ability to catch and return each ball for completely realistic rally play.
Designs
Once the robot completes its testing phase, the hardware design files and embedded control software will be released under an open licensing arrangement that empowers builders, researchers, educators, developers, and manufacturers to create, customise, and evolve the platform for themselves.
Hardware
Mechanical 3D models, wiring layouts, and bill of materials for the rover, launcher, and reloader.
Software
Roving and launching control software that is embedded in the hardware.
Licence
An arrangement that lets builders, researchers, educators, developers, and manufacturers customise and evolve the platform.
Community
Reproduce the results, file findings, propose hardware revisions, and publish derivative platforms.
MORE LAB NOTES
HardwareAug 31, 2026
New drive system, new computation and controllers, new wrangling system, embedded batteries and 360-degree sensors make the 2026 BallBOPPer™ Rover a faster, stronger and more efficient mover on a tennis court.
ResearchAug 27, 2026
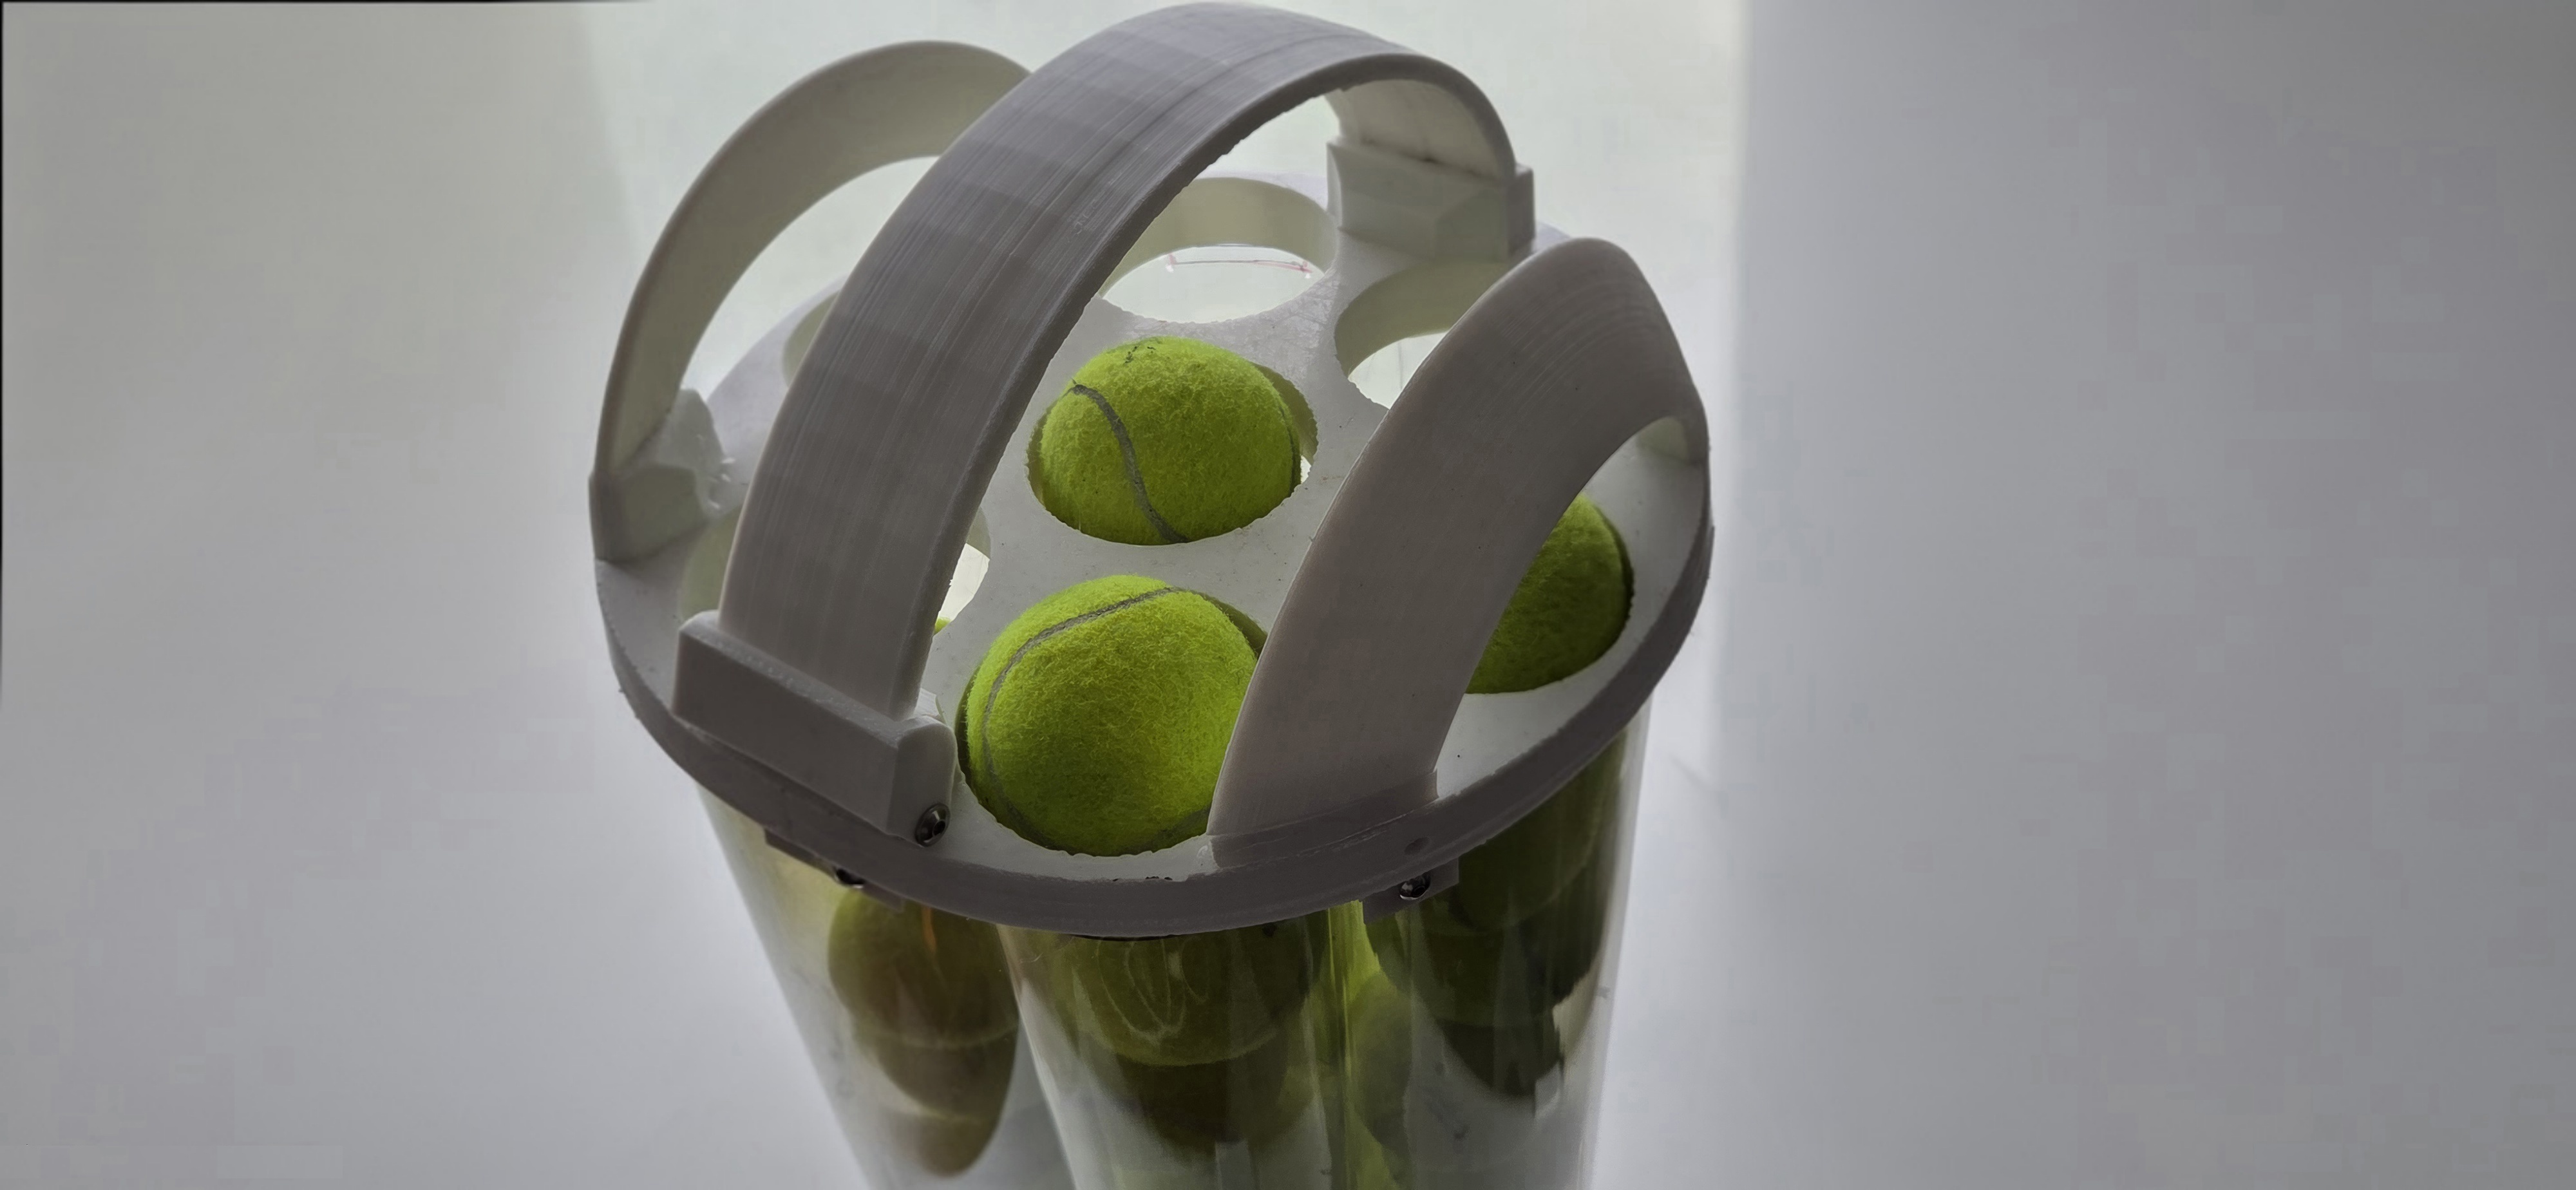
The Ball Revolver is an important addition to the 2026 BallBOPPer™ that provides a number of useful capabilities.
ResearchAug 25, 2026
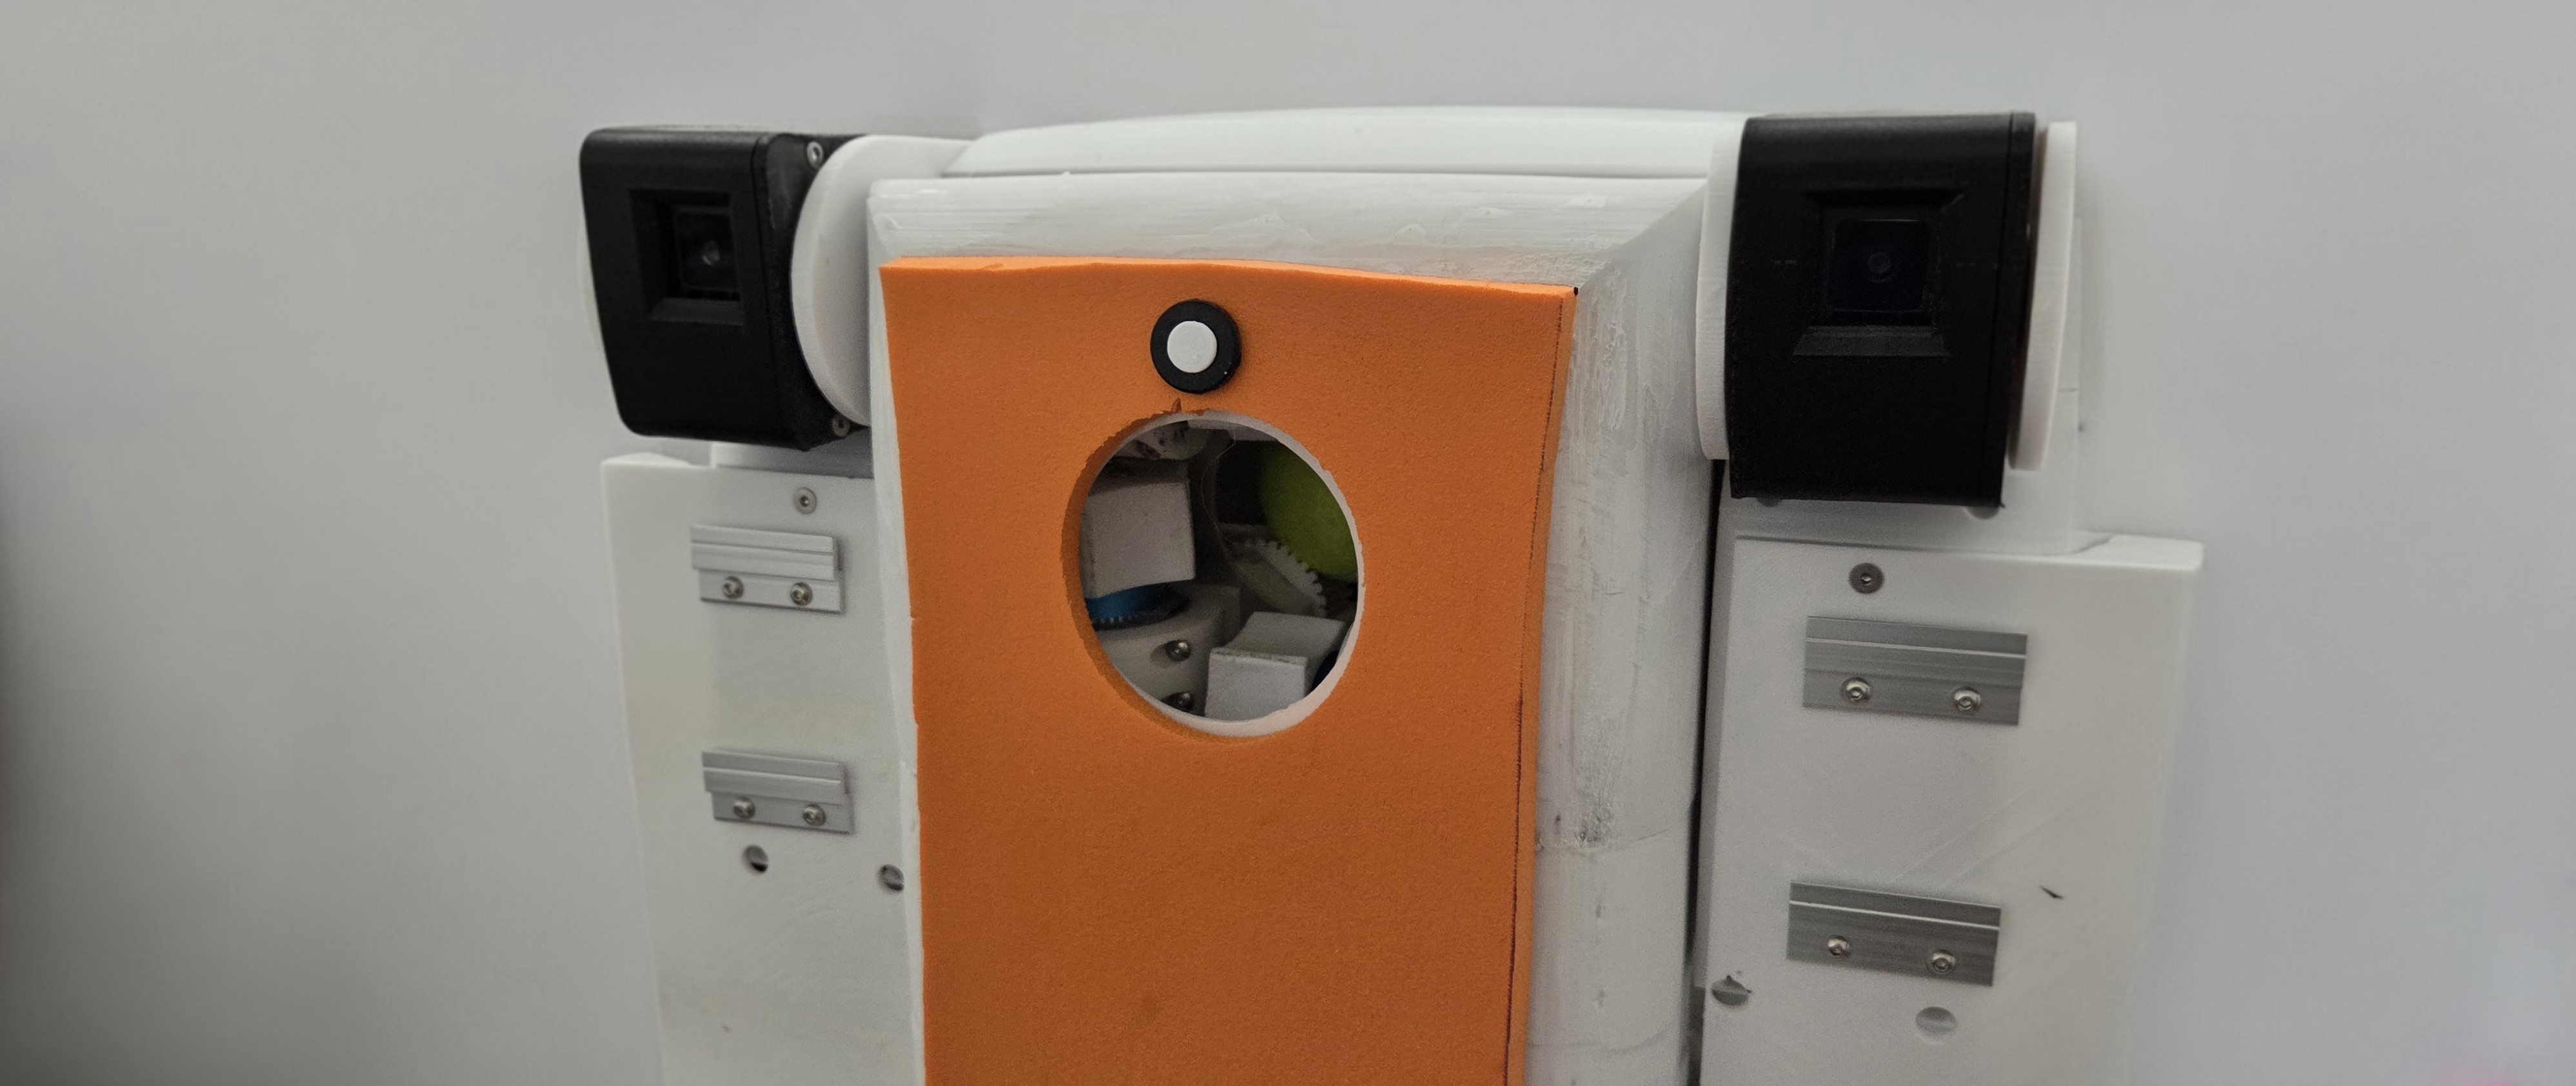
The Launch Head has evolved along with everything else about the BallBOPPer™ 2026 but the most important aspects of the design are much the same as the original patent.
New papers, data tables, and design-file drops, sent when they are published. No marketing.